Four-dimensional (4D) imaging radar is a high-resolution sensing technology that adds vertical information (elevation) to traditional 3D radar (range, azimuth, Doppler). By capturing 3D spatial data plus vertical, it creates dense, high-resolution point clouds that enhance object detection in autonomous vehicles, surveillance, and industrial applications, regardless of lighting or weather.
It’s also used for in-cabin sensing of vehicle occupants, see: “How is radar used for automotive in-cabin sensing?”
The number of 4D radars used in advanced driver assistance systems (ADAS) varies widely. An entry-level system may have a single front-facing radar, while higher levels of autonomy require more and higher-performance radars.
High ADAS performance levels can require up to 9 or more radars, including front, rear, side, and corner locations, with varying requirements for sensing distances and resolutions (Figure 1). In addition to being dedicated to specific applications like lane changing or collision avoidance, the various radar images can be stitched together to provide a 360° awareness of the surroundings.
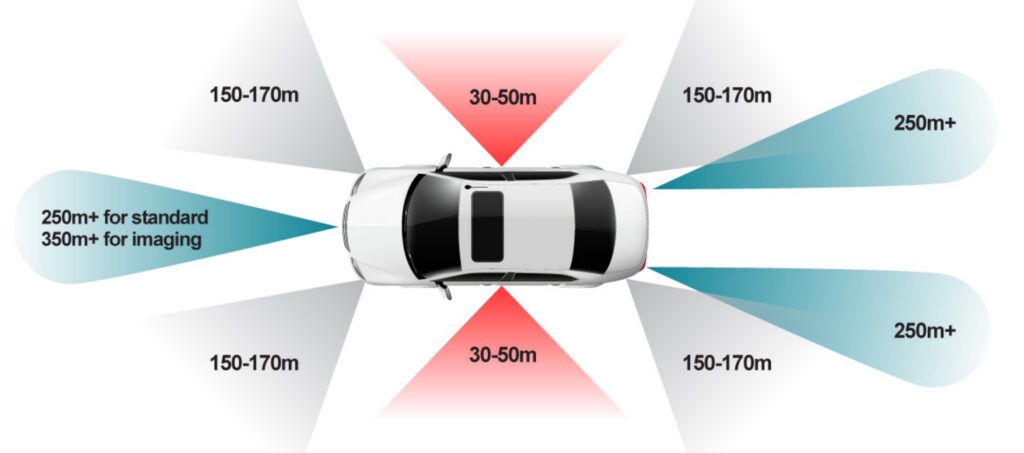
The basics
A 4D imaging radar uses a multiple-input multiple-output (MIMO) antenna array to create hundreds or thousands of channels, increasing angular resolution and enabling the creation of a dense “point cloud” representing the shapes and positions of multiple objects with high precision. The point cloud enables both object detection and detailed mapping of the environment, including:
- Distance measurements to support collision avoidance, blind spot detection, safe lane changes, and other functions.
- Velocity measurements track the relative speed of moving objects and anticipate possible hazards.
- Angular resolution can precisely determine the relative position of moving and stationary objects.
- Multi-object tracking for simultaneous monitoring of vehicles, pedestrians, cyclists, and other objects in the vicinity.
The addition of elevation measurements allows a 4D radar to detect the height of objects. That enables the system to distinguish between a stalled car underneath a bridge and the bridge located overhead.
Frequency-modulated continuous wave (FMCW) technology is almost universally used for 4D imaging radar, including automotive, drones, industrial process control, robotics, and other applications. FMCW continuously emits radio waves and compares the reflected waves to measure distance, velocity, and angle.
Next-gen performance
Like most areas of electronics technology, 4D radar systems are being pushed for increased performance and lower costs. For example, antenna technology has been developed that uses molded air-filled tunnels to guide waves, reducing signal loss and improving sensitivity for higher resolutions.
Systems are moving from expensive monolithic microwave integrated circuits (MMICs) to CMOS technology for better integration and cost-effectiveness.
As 4D imaging radar becomes more widely used in a greater variety of applications, integrated modules are also being increasingly used to control costs and improve performance. Cascading multiple integrated modules rather than individual transceiver chips reduces signal loss, synchronization errors, and thermal constraints. It can also reduce assembly costs, enable smaller PCB footprints, and simplify manufacturing.
Using integrated waveguide antennas or multi-chip modules can also enable higher angular resolution and longer range without high power consumption and the complex calibrations required when cascading individual chips.
Location complication
Urban planners are particularly interested in maximizing the benefits of 4D imaging radar for enhanced safety to both drivers and pedestrians. As a result, two key use cases have been developed: the Highway Pilot and Urban Pilot. Imaging radar is expected to satisfy the needs of both.
The Highway Pilot focuses on the open road and requires 4D radar that can detect rapidly moving objects over relatively long distances to support safe high-speed maneuvering. The Urban Pilot focuses on more complex environments in closer proximity, including both moving and stationary objects, and requires simultaneous detection and classification of multiple objects in real time.
Requirements for the Highway Pilot include lane-level accuracy and a front-looking field of view (FOV) of 10° to 30° looking at the immediate path ahead. The Urban Pilot requires a wider field of view for short and mid-range objects with 360° coverage, with corner radars offering up to 150° FOV to detect cross-traffic and pedestrians.
The Urban Pilot also requires higher angular resolution to separate closely located objects in dense, low-speed traffic. In both cases, the expectations for the number of imaging radars on a vehicle and their performance will increase in the future (Figure 2).

Summary
4D imaging radar provides high-resolution images used in a variety of applications from automotive ADAS for autonomous driving to drones, industrial process control, and robotics. It can use multiple radars to provide more complete situational awareness, and performance demands are increasing over time, while costs are expected to decline.
References
4D Imaging High-Resolution Radar, Explained., Arbe Robotics
4D Millimeter-Wave Radar in Autonomous Driving: A Survey, arXiv
Achieving 4D radar imaging with a single-chip, 8-by-8 , cascadable transceiver, Texas Instruments
From Weather to Workzones: Expanding the Use of 4D Imaging Radar, Bitsensing
LiDAR vs RADAR: How 4D Imaging RADARs and FMCW LiDARs disrupt the Autonomous Tech Industry, Think Autonomous
Simulate an Automotive 4D Imaging MIMO Radar, MathWorks
The Evolution of 4D Imaging Radar: Unlocking the Future of Autonomous Driving, NXP
What Is 4D Imaging Radar?, Aptiv
What Is 4D Imaging Radar for ADAS and ITS?, Zilai Technology
Related EEWorld Online content
What are the latest advances in radar and LiDAR technologies for sensor fusion: part 1
What are the design challenges when using SPAD sensors?
How do holographic displays and spatial computing work and what can you do with them?
What is a metalens and what’s it good for?
What are phased array antennas, and how do they work?
Leave a Reply
You must be logged in to post a comment.